SceneGEMS: Scenario Generation and Execution Framework for the Safety Assurance of Maritime Autonomous Surface Vehicles
- Period
- Oct 2026
- Organisation
 ACM/IEEE MODELS 2026 (Tools and Demonstrations)
- Location
- Meliá Costa del SolPaseo Marítimo de Torremolinos 11, 29620 Torremolinos, Málaga, Spain
- Posted
Tool paper presenting SceneGEMS, an integrated framework that generates functionally complete COLREGS assurance suites, executes them in simulation with the vessel under test in the loop, and monitors COLREGS compliance at runtime.
- 12-minute live tool demonstration at MODELS 2026
- Demo video on YouTube
Dominik Frey, Ulf Kargén, and Dániel Varró. 2026. SceneGEMS: Scenario Generation and Execution Framework for the Safety Assurance of Maritime Autonomous Surface Vehicles. Proceedings of the ACM/IEEE 29th International Conference on Model Driven Engineering Languages and Systems: Companion (Tools & Demonstrations), 219–223. https://doi.org/10.1145/3837062.3838872
This short paper presents SceneGEMS as a tool. The project page has the architecture and technical details. This page covers the paper and the demo.
The pitch
Simulation-based testing of autonomous vessels usually treats scenario generation, simulation and compliance monitoring as separate problems with separate tools. SceneGEMS integrates them into one modular workflow:
- generate functionally complete assurance suites from high-level specifications, with interactive visualisation of the resulting multi-vessel encounters;
- instantiate and execute the generated scenarios in simulation;
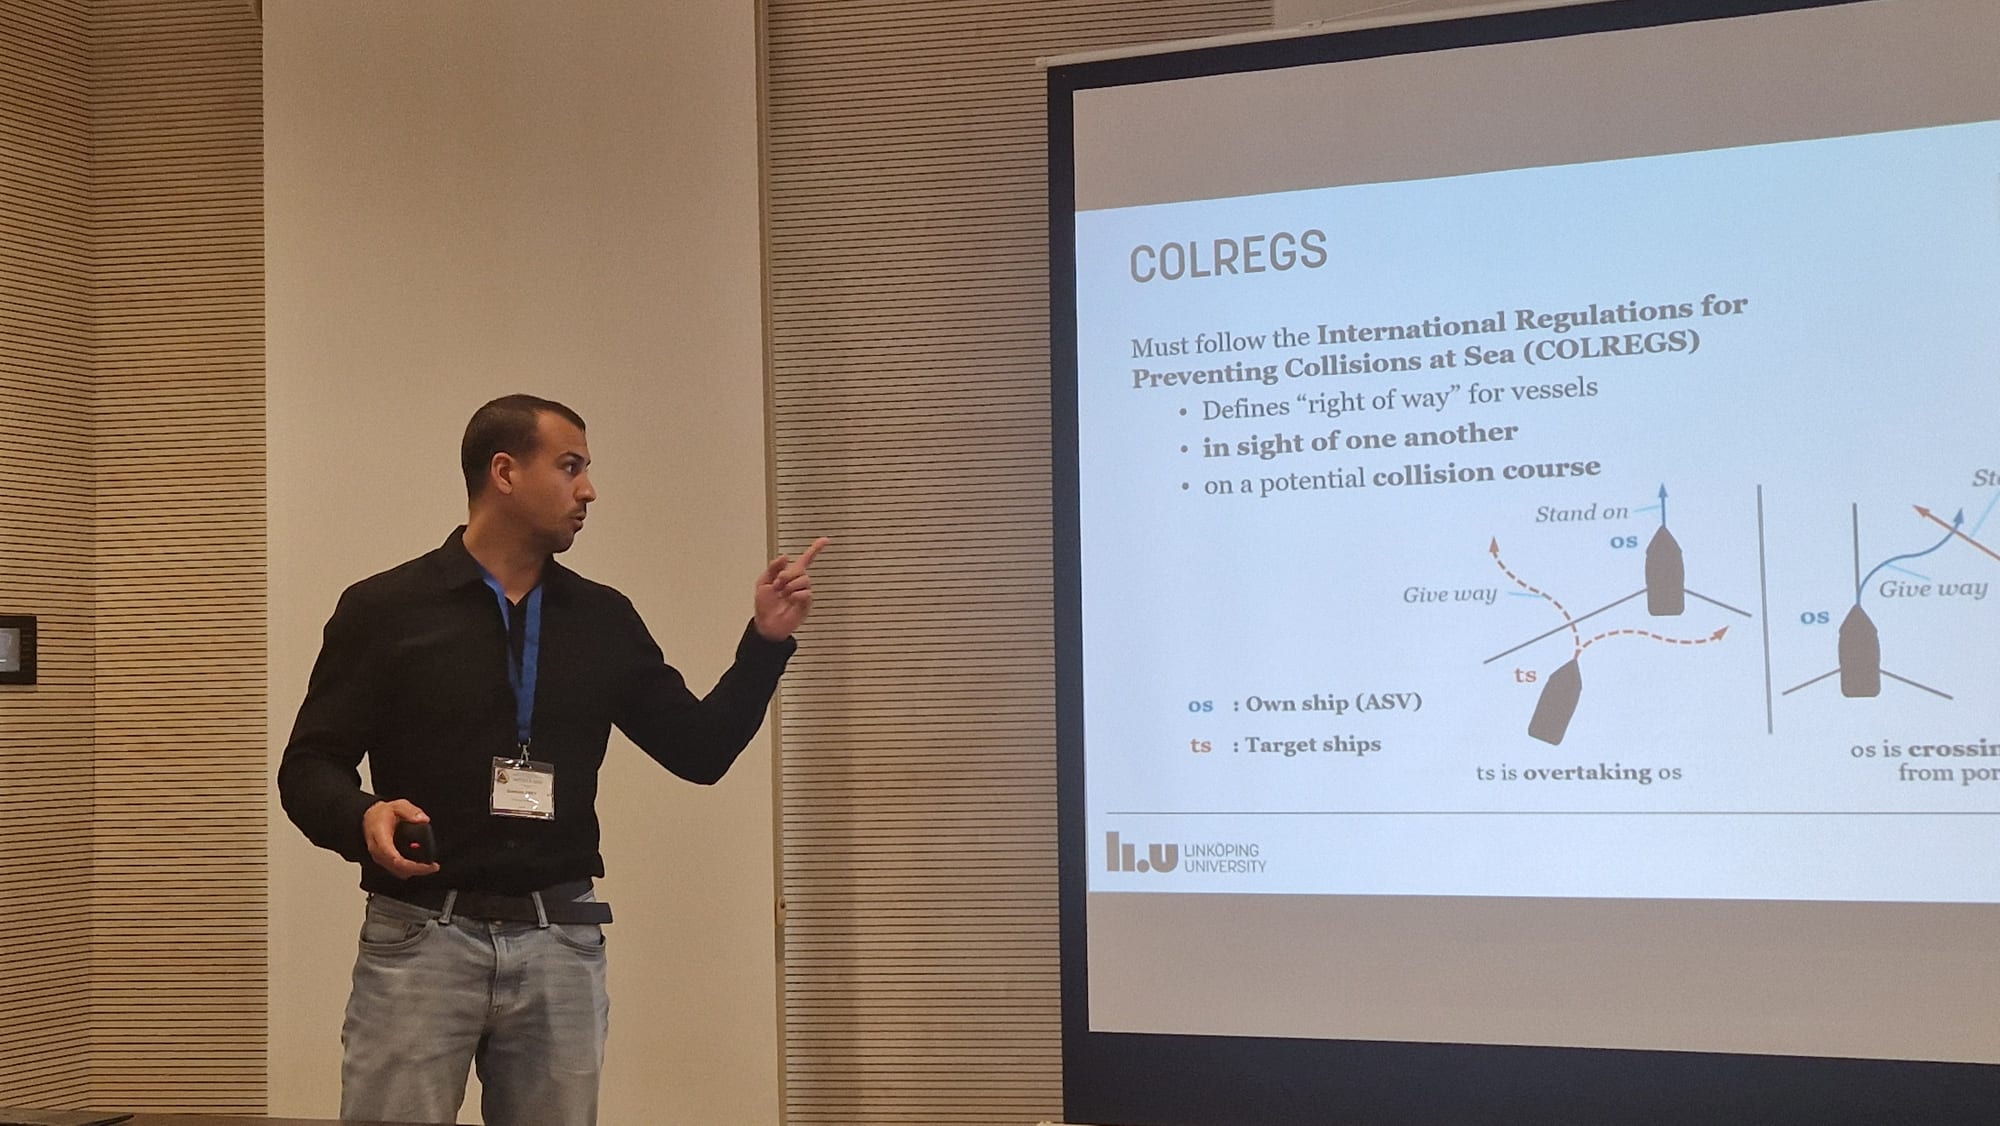
- monitor COLREGS compliance at runtime, with real-time visual feedback and exportable assurance evidence.
Practitioners can configure the simulated environment, the communication interfaces and the physical model of each vessel. The ASV under test is connected through software-in-the-loop or hybrid set-ups that mix real and simulated vessels.
The demo
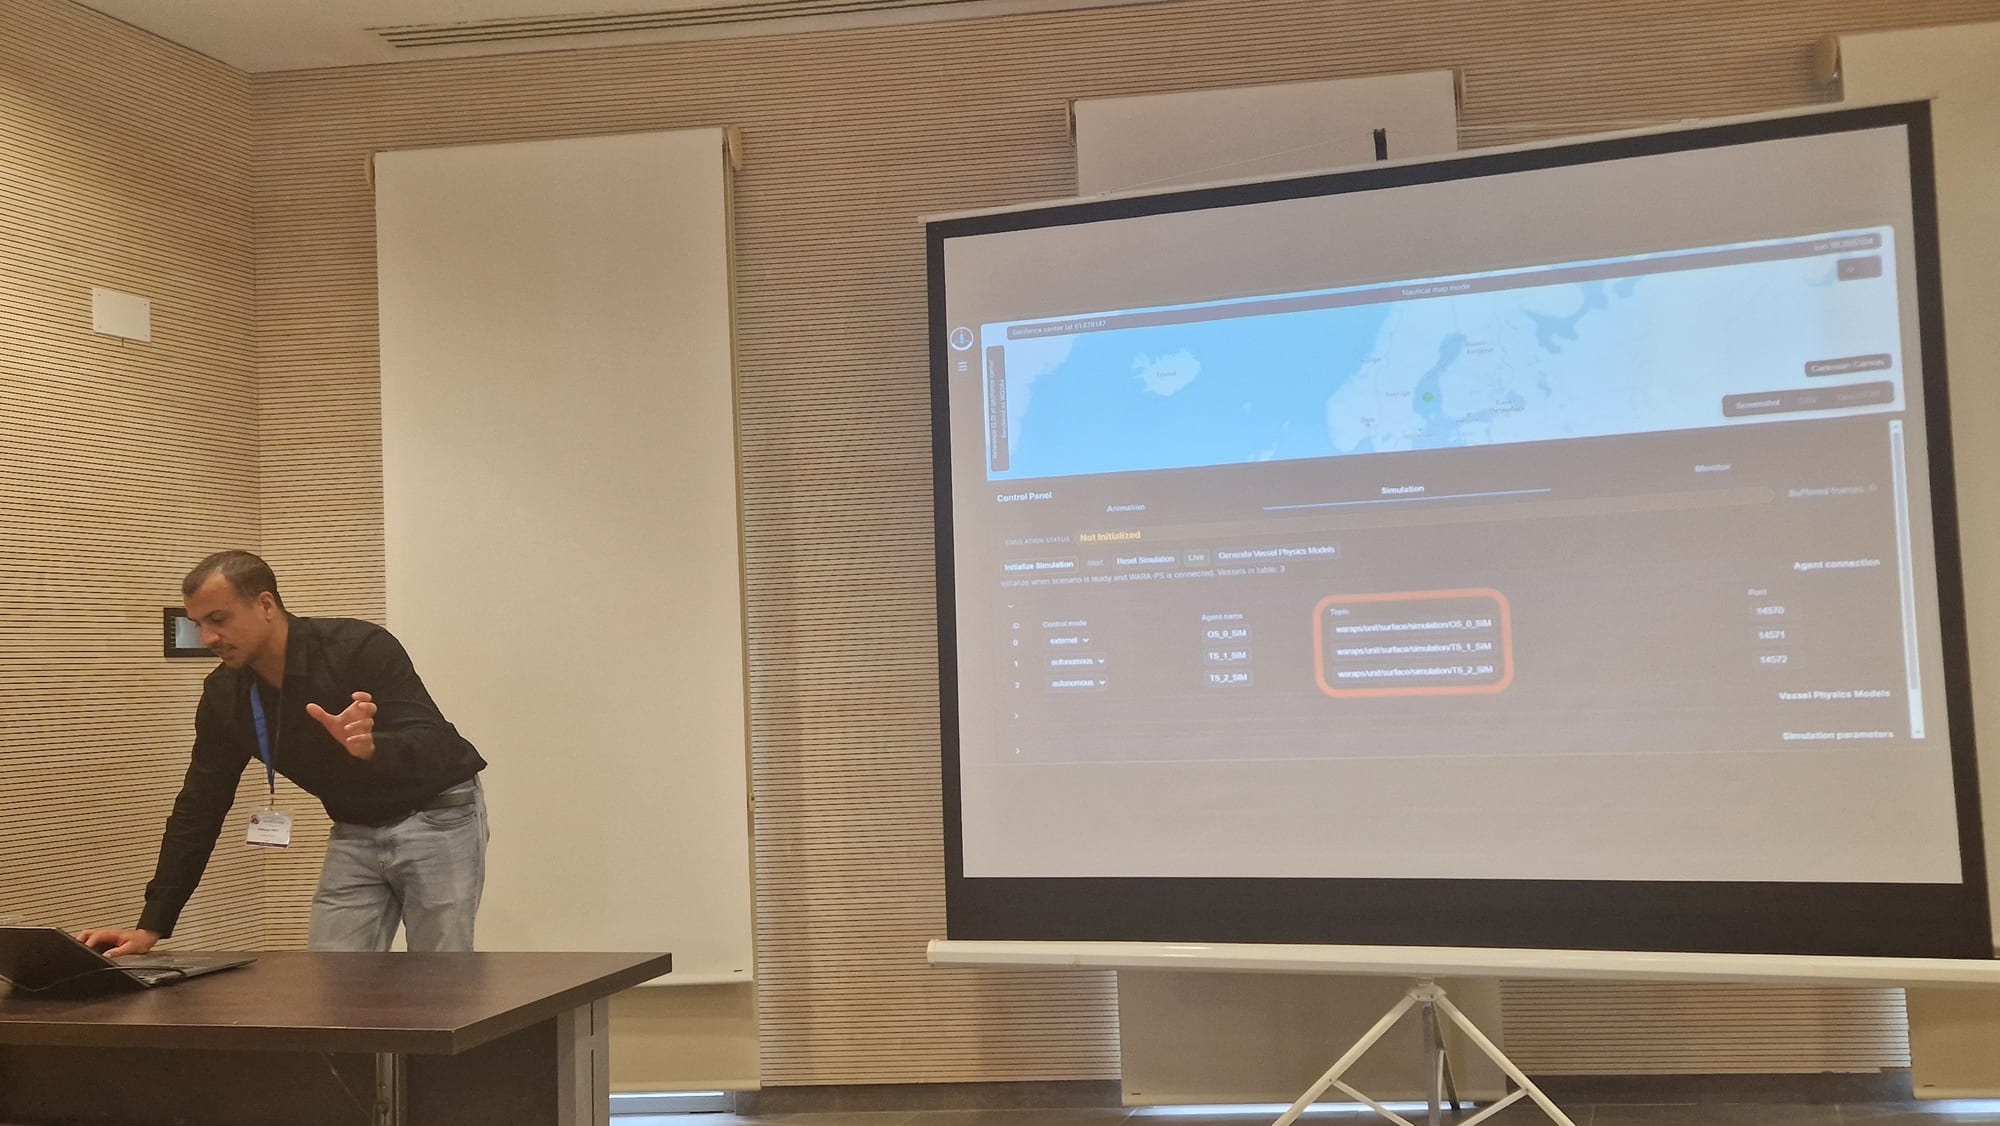
In the 12-minute demo I walked through the full loop. First I picked a preset (for example 3 vessels, 0 obstacles), generated a batch of initial scenes and previewed their animation. Then I configured each simulated vessel (external control over UDP, or autonomous trajectory following over MQTT in the WARA-PS infrastructure) and ran the simulation. The monitor panel reports emerging COLREGS situations and rule violations at every timestamp. In the demo scenario no compliant controller was connected to the own ship, so it failed to take early and substantial action and the monitor flagged violations ending in collisions.
Video
Gallery
References
- D. Frey, U. Kargén, D. Varró. 2026. SceneGEMS: Scenario Generation and Execution Framework for the Safety Assurance of Maritime Autonomous Surface Vehicles. In Proc. ACM/IEEE 29th Int. Conf. on Model Driven Engineering Languages and Systems: Companion, 219–223. doi.org/10.1145/3837062.3838872