WARA-PS Demonstration Week 2026: Assuring the Safety of Maritime ASVs with SceneGEMS
- Period
- 14 Sep 2026
- Organisation
 WASP Research Arena for Public Safety (WARA-PS)
- Location
- Gränsö Slott, WARA-PS test siteGränsövägen, 593 92 Västervik, Sweden
- Posted
Presentation of SceneGEMS as an end-to-end framework, from scenario generation to simulation execution, at the WARA-PS demonstration week, where WASP researchers and partners show autonomous systems working in a shared maritime arena.
- SceneGEMS integrated with the WARA-PS core system
- Simulated vessels driven over WARA-PS MQTT topics
WARA-PS, the WASP Research Arena for Public Safety, gives researchers a shared infrastructure of real and simulated vehicles, the core system, and an archipelago test site at Gränsö near Västervik. The yearly demonstration week is where projects show what works on that infrastructure.
My presentation, Assuring the Safety of Maritime Autonomous Surface Vehicles with SceneGEMS: An End-to-End Framework from Scenario Generation to Simulation Execution, walked through:
- The assurance problem. COLREGS compliance, why multi-vessel scenarios are ambiguous, and why functional completeness matters.
- The pipeline. Functional equivalence classes → logical scenarios → initial scenes → trajectories, built on the Refinery graph solver and constraint solving.
- The integration. SceneGEMS publishes every simulated vessel on a WARA-PS MQTT topic. A vessel can follow its generated mission autonomously or be handed to an external ASV controller, and a runtime monitor evaluates COLREGS compliance.
- The roadmap. Orchestration through the WARA-PS core system, ASV runtime monitoring, trajectory validation, and execution at scale.
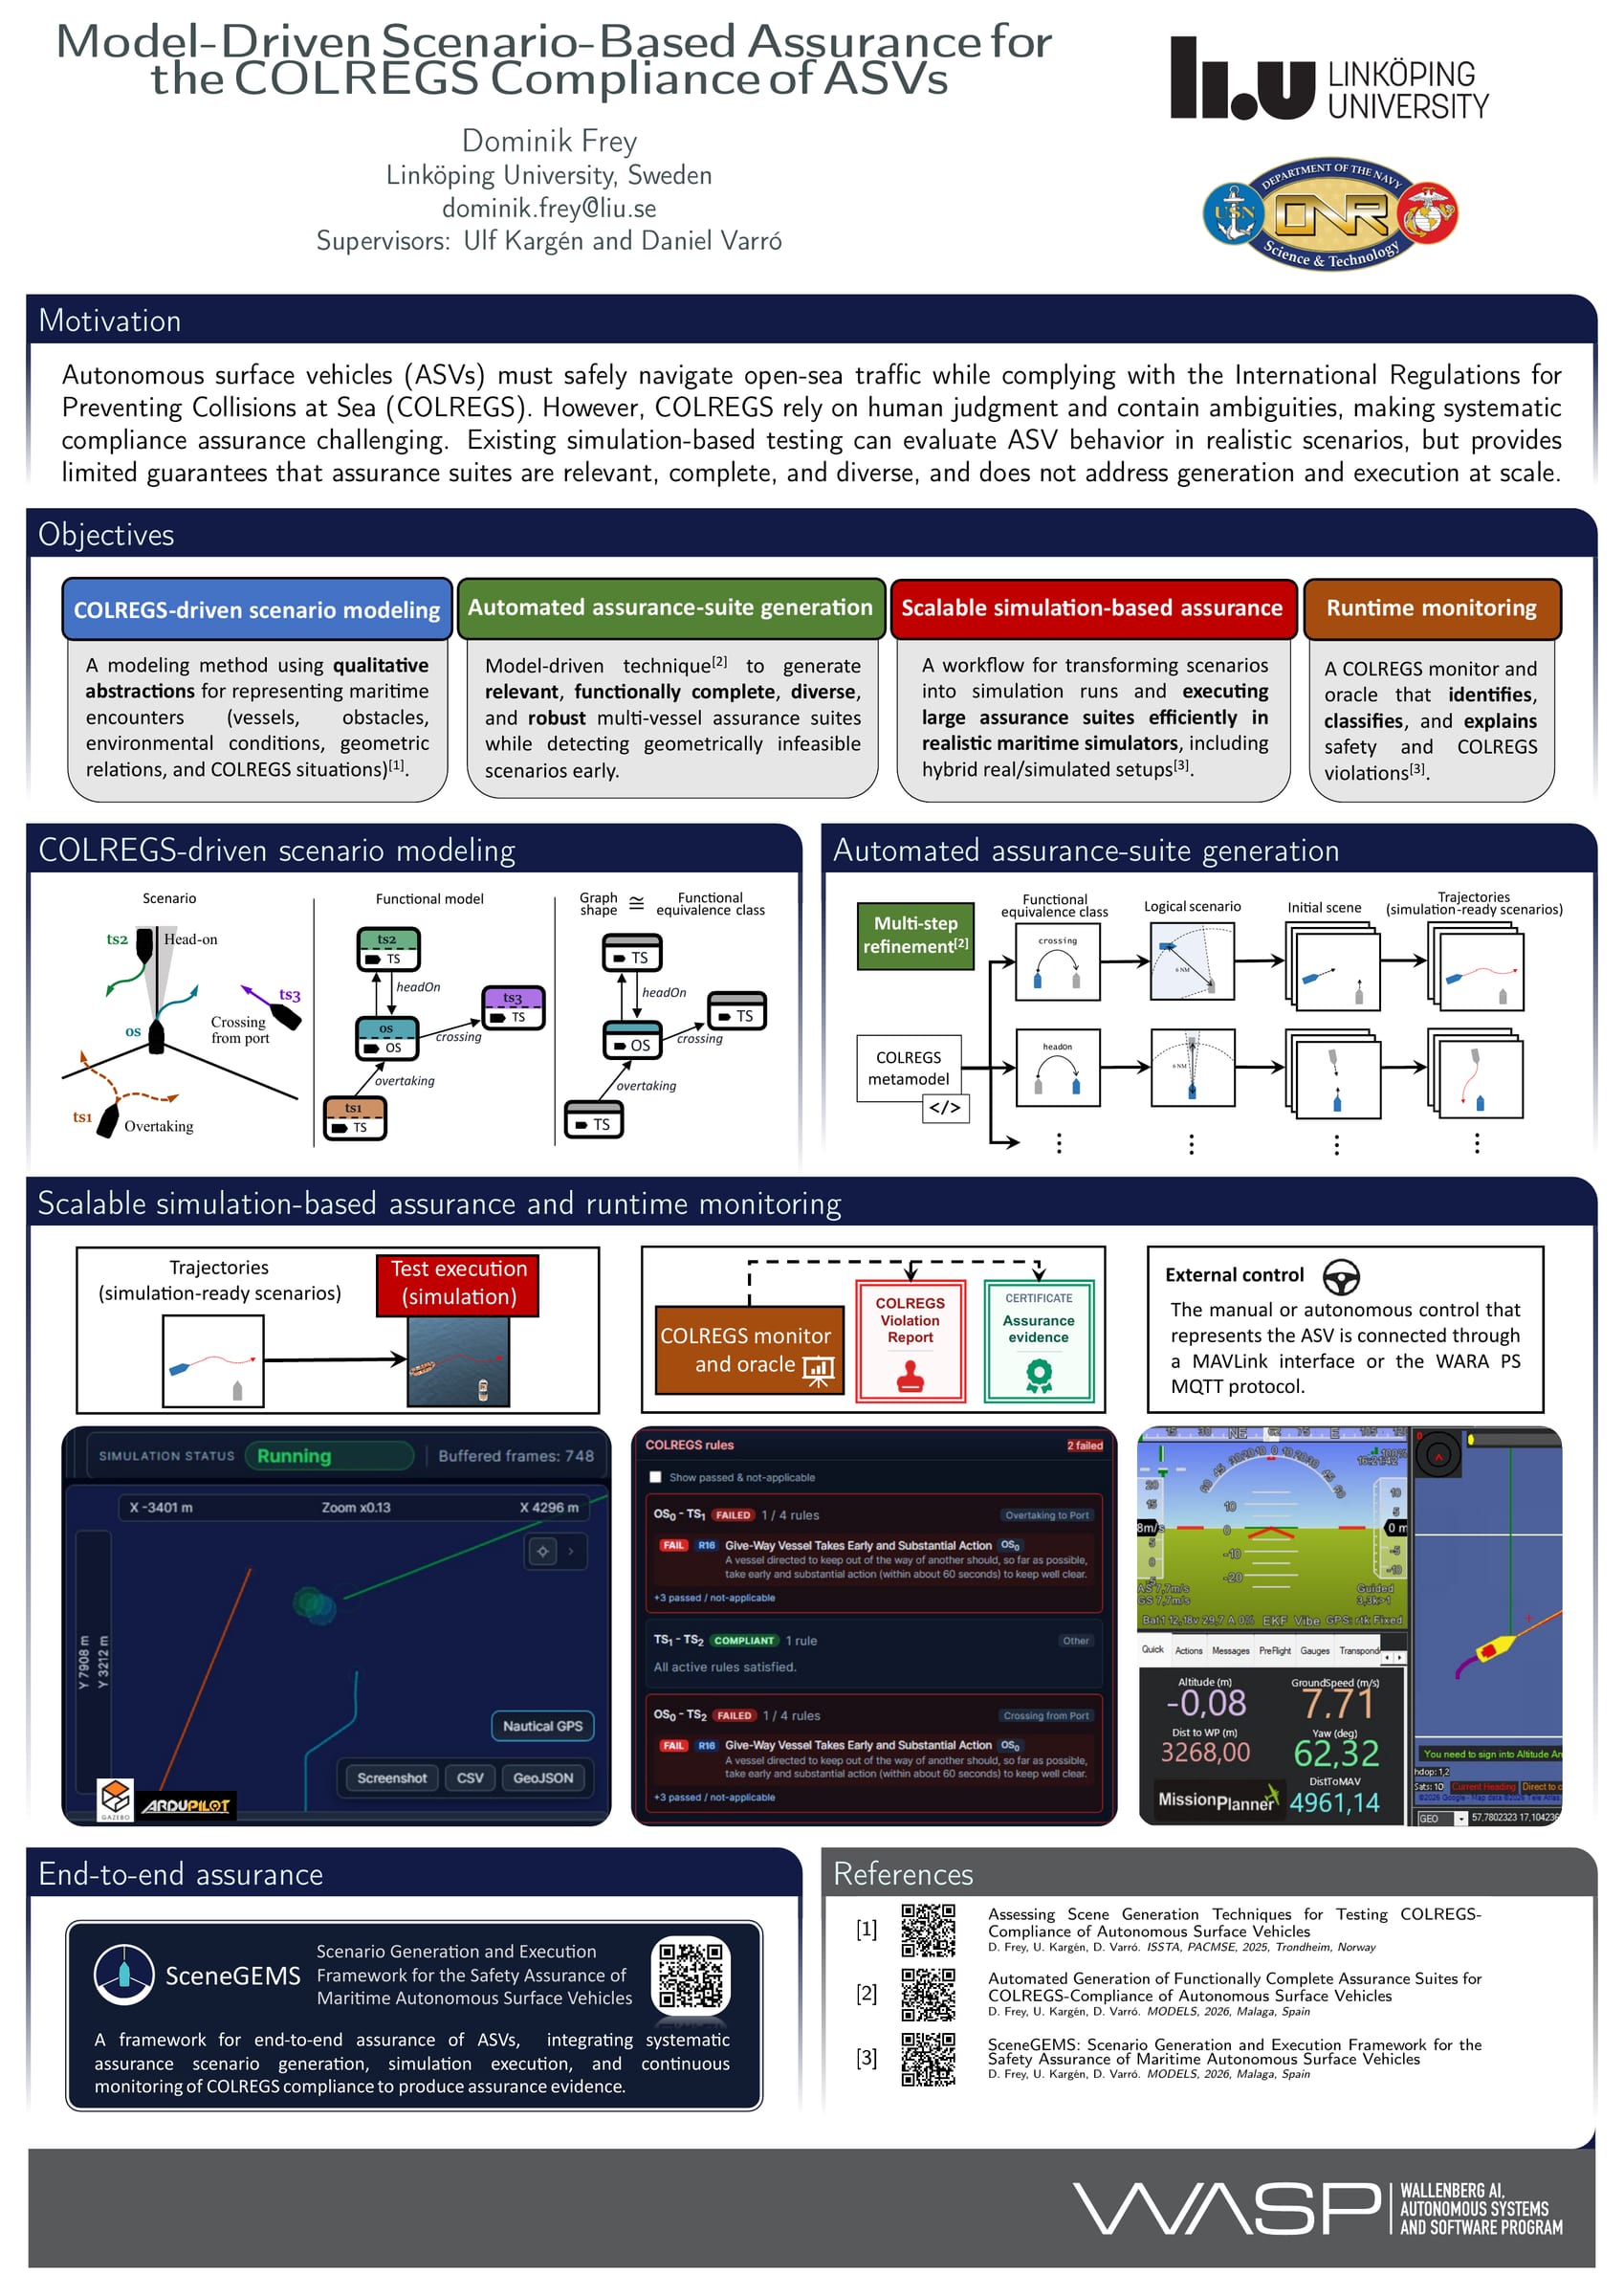
I also presented a poster, Model-Driven Scenario-Based Assurance for the COLREGS Compliance of ASVs, which covers the same work: scenario modelling, assurance-suite generation, simulation at scale and runtime monitoring.